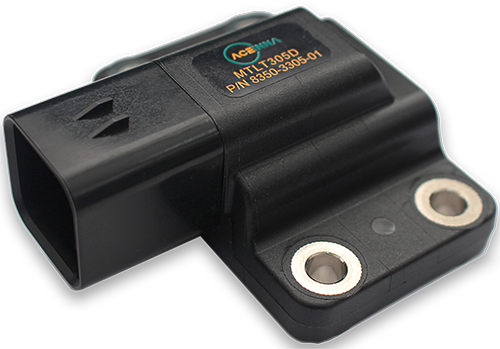
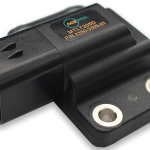
ACEINNA MTLT335D Dynamic Tilt Sensor / IMU
(In stock)
| Product Name | ACEINNA MTLT335D Dynamic Tilt Sensor / IMU |
| Model Number | MTLT335D (Tilt Sensor / IMU series) |
| Brand | ACEINNA |
| Category | Tilt Sensor / Inertial Measurement Unit (6-DOF strap-down IMU) |
| Country Origin | United States |
| Material | Rugged, sealed over-molded plastic (or optional rugged housing) — designed for industrial and vehicle-mount environments. |
| Applications | Measures pitch and roll (tilt), 3-axis acceleration and angular rate — used for boom/bucket attitude on construction or agricultural vehicles, vehicle-dynamics monitoring, robotics control, camera or antenna stabilization, and other dynamic tilt/attitude/position sensing in tough environments. |
The ACEINNA MTLT335D is a high-performance, 6-degree-of-freedom inertial sensor (accelerometer + gyroscope) packaged in a rugged sealed housing, engineered for demanding, motion-intensive environments such as construction, agriculture, mobile machinery, and robotics.
It features a triple-redundant sensor architecture (3-axis MEMS accelerometers + 3-axis rate gyros, each triplicated) combined with onboard signal processing (ARM-M4 processor + Kalman-filter-based sensor fusion) to compute reliable pitch and roll (tilt), even under vibration, movement, or dynamic loading — making it suitable as a dynamic tilt sensor (not just static inclination
يبدو أنه لا توجد تعليقات حتى الآن.